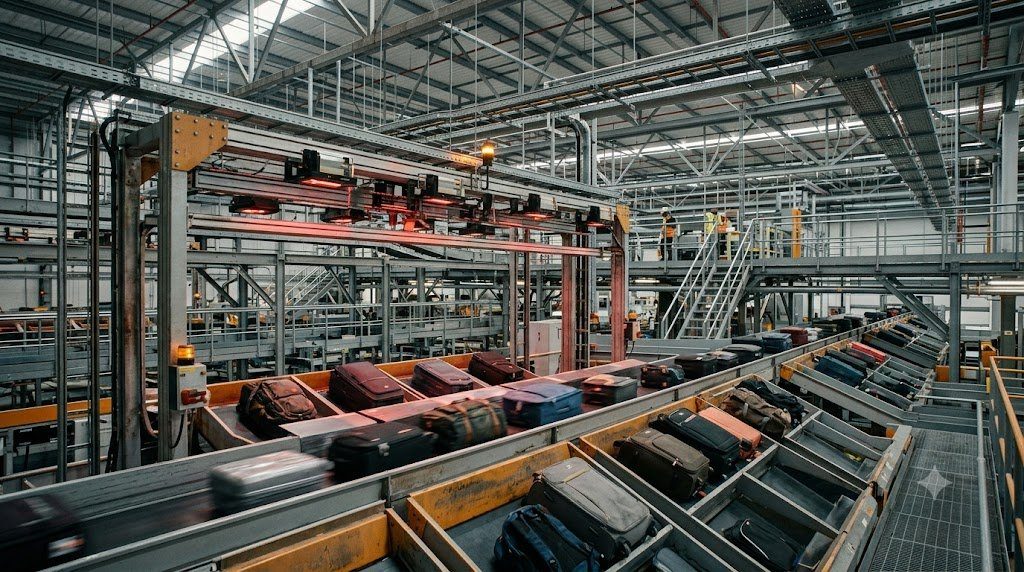
Behind the passenger terminals of mega-hub international airports lies one of the most sophisticated industrial automation and material-handling networks in the world: the Automated Baggage Handling System (BHS). Handling upwards of 50,000 to over 150,000 pieces of checked luggage daily, a modern BHS spans tens of kilometers of high-speed conveyor belts, automated multi-level explosive detection system (EDS) x-ray screening matrices, early baggage storage (EBS) crane warehouses, and destination-coded vehicle (DCV) tracks operating via Ultra-High-Frequency (UHF) RFID Tracking and High-Speed Tilt-Tray Sorters.
Under IATA Resolution 753, airlines and airport authorities are legally mandated to track every checked bag across four mandatory operational custody milestones: Passenger Handover (Check-in), Aircraft Loading (Ramp), Transfer Custody between carriers, and Passenger Delivery at Arrival Carousel. Complying with this global tracking mandate has accelerated the transition from legacy optical 1D barcodes to automated passive UHF RFID Bag Tags.
Radio Frequency Identification (RFID): The 900 MHz EPC Gen 2 Standard
For decades, baggage tags utilized printed 1D optical barcodes. However, optical laser scanners suffer from an inherent physical constraint: line of sight. If a baggage tag is twisted, crumpled, folded beneath the luggage bag, or smudged with dirt, laser scanners fail to read, causing missed read rates of 8% to 15% and routing bags to manual encode holding loops.
Modern airports deploy passive Ultra-High-Frequency (UHF) RFID Tags (EPC Class 1 Gen 2 / ISO 18000-6C) embedded directly within paper baggage tags. Operating between 860 MHz and 960 MHz:
- Backscatter Modulation: Ground antenna arrays emit electromagnetic RF waves that power the microscopic microchip inside the tag via inductive and capacitive coupling; the tag replies by modulating its antenna impedance, reflecting its unique 96-bit Baggage Tag Number.
- Non-Line-of-Sight Read Rates: UHF RFID portals read baggage tags through leather, nylon fabric, and plastic shells at speeds exceeding 99.5% read accuracy, even as bags travel past on conveyors at 3.0 meters per second.
High-Speed Sortation Architectures: Tilt-Tray vs. Cross-Belt Sorters
At the mechanical core of airport baggage sortation are continuous-loop high-speed sorter machines moving at speeds up to 2.5 to 3.0 meters per second (10 km/h):
- Tilt-Tray Sorters: Luggage rides on a continuous train of carriages fitted with mechanical trays. When the carriage reaches the specific flight make-up lateral chute (lateral spur), an electric solenoid or linear induction motor tilts the tray smoothly to a 45-degree angle, discharging the bag into the flight baggage container.
- Cross-Belt Sorters: Each carriage carries an independent bidirectional motorized miniature conveyor belt running orthogonally to the train’s travel direction. Cross-belt sorters actively drive luggage off the carriage with precise velocity vector control, ensuring gentle handling and tight spacing between discharge chutes.
| Baggage Handling Subsystem | Mechanical Transport Technology | Operating Speed Range | Sorting Accuracy Rate | Key Operational Function |
|---|---|---|---|---|
| Check-in Induction Belt | Variable-Speed Friction Belts | 0.5 – 1.0 m/s | 100% Static Weighing | Weight Validation & Tag Printing |
| Tilt-Tray Loop Sorter | Continuous Mechanical Linkage Carriages | 2.0 – 2.5 m/s | > 99.8% Sorting Accuracy | Primary Flight Chute Allocation |
| Cross-Belt Sorter Loop | Individual Motorized Carriage Belts | 2.5 – 3.0 m/s | > 99.9% Sorting Accuracy | High-Density Hub Sortation |
| Individual Carrier System (ICS) | Tote Box on High-Speed Twin-Trolley | 5.0 – 10.0 m/s (36 km/h) | 100% RFID Tote Containment | Long-Distance Inter-Terminal Tunnel Transit |
Individual Carrier Systems (ICS): High-Speed Tote Box Tunnel Transit
At mega-hub airports with distant terminals separated by kilometers (such as London Heathrow Terminal 5 or Incheon Airport), conventional conveyor belts are too slow. These airports utilize Individual Carrier Systems (ICS).
The passenger’s bag is loaded into a dedicated, impact-resistant plastic Tote Box fitted with an embedded RFID microchip. The tote travels along high-speed steel tracks powered by linear induction motors at velocities exceeding 10 meters per second (36 km/h) through subterranean inter-terminal tunnels. Because the bag never touches a moving roller directly, luggage damage claims are cut by over 80%.
Multi-Level Explosive Detection System (EDS) Screening Matrices
Under international aviation security directives (TSA and ECAC standards), every checked bag must undergo automated 100% Hold Baggage Security Screening before loading onto an aircraft:
- Level 1 (High-Speed Computed Tomography – CT): Automated multi-slice medical-grade CT scanners scan bags at high speed, analyzing X-ray attenuation coefficients and material mass density to detect explosive compounds automatically. Clean bags clear in under 5 seconds.
- Level 2 & 3 (Image Resolution & Trace Detection): Suspicious bags are diverted automatically into secondary holding spurs where security screeners rotate 3D virtual CT images on workstations, or divert bags for physical explosive trace detection (ETD) swab testing.
High-Speed Tilt-Tray and Cross-Belt Sortation Kinematics, RFID Telemetry and IATA Resolution 753
Modern mega-hub international airports process over 100,000 checked baggage items daily through automated Baggage Handling Systems (BHS) spanning tens of kilometers of underground high-speed conveyance networks. The operational core of modern BHS infrastructure consists of high-capacity Tilt-Tray Sorters and Cross-Belt Sorters operating at linear conveyance speeds of 2.5 to 3.0 m/s, coupled with autonomous Destination Coded Vehicles (DCV) operating on dedicated tracked guideways at speeds exceeding 10 m/s (36 km/h).
The mechanical kinematics of cross-belt sortation rely on individual motorized conveyor belts mounted transversely atop carrier carts moving continuously along closed-loop tracks. When a bag reaches its destination chute leading to a specific flight’s make-up carousel, an optical sensor triggers the localized carrier cross-belt motor. The discharge velocity vector ($\vec{v}_{discharge}$) combines vectorially with the carrier linear forward velocity ($\vec{v}_{carrier}$) to smoothly eject the bag onto the diversion slide with zero lateral tumbling or physical impact shock:
v⃗net = v⃗carrier + v⃗cross-belt | θeject = arctan(|v⃗cross-belt| / |v⃗carrier|)
To eradicate mishandled baggage costs, IATA Resolution 753 mandates continuous chain-of-custody tracking across four mandatory custody transfer milestones: (1) Passenger Check-in Bag Tagging, (2) Aircraft Ramp Loading, (3) Inbound Inter-Line Flight Transfer, and (4) Arrival Baggage Reclaim Delivery. Legacy optical barcode tags suffer from read failures ($85\% – 92\%$ read rates) caused by crumpled tags or obscured line-of-sight. Modern baggage tags embed UHF RFID inlay chips (860 to 960 MHz EPC Gen 2 standard), enabling high-speed radio tunnel readers to achieve $> 99.5\%$ first-pass read rates across dense conveyor luggage streams.
Standard 3 Computed Tomography (CT) Explosive Detection System (EDS) Integration
In compliance with international ECAC and TSA security mandates, all checked baggage must pass 100% automated in-line security screening via European Standard 3 certified Computed Tomography (CT) Explosive Detection Systems (EDS). These rotating gantry scanners capture thousands of dual-energy X-ray projection slices, reconstructing 3D volumetric images that calculate atomic effective number ($Z_{eff}$) and physical density ($\rho$) for every item in luggage. Automated detection algorithms flag explosive compounds without human intervention, routing cleared bags to high-speed sortation while automatically diverting suspect luggage to Level 2 and Level 3 manual operator inspection stations.
Mega-Project Systems Integration Failure: The Denver International Airport (DIA) BHS Teardown
The opening of Denver International Airport in 1995 remains the definitive engineering case study in large-scale automated material handling systems failure. DIA was designed with a fully automated, centralized airport-wide Baggage Handling System engineered to transport checked luggage between the main terminal and three remote concourses via thousands of high-speed Destination Coded Vehicles (DCVs) operating across 42 kilometers of track.
The software and electromechanical integration proved overwhelmingly complex. Optical barcode scanners failed to read misaligned luggage tags, causing sortation computers to lose bag tracking identities. Software timing bugs caused mechanical diverters to misfire, tossing luggage from high-speed carts and jamming conveyance tracks. In multiple high-profile trials, luggage was shredded, misrouted to incorrect concourses, or piled into catastrophic conveyor gridlocks. The BHS failures delayed the opening of Denver International Airport by 16 months, incurring over $560 million in cost overruns before the airport abandoned the automated system for departing flights in favor of conventional tug-and-cart operations.
The Denver BHS failure revolutionized airport baggage automation design. Modern airports completely abandoned monolithic centralized software controllers in favor of distributed, modular Programmable Logic Controllers (PLCs) communicating over redundant Industrial Ethernet (PROFINET / EtherNet/IP). Each conveyor zone, merge junction, and sortation loop operates as an autonomous self-regulating cell. If a single conveyor motor or sensor faults, the localized PLC reroutes luggage around the faulted node without crashing the wider airport baggage network.
Early Bag Storage (EBS) Crane Automation and High-Density Tote Matrix Storage
To support multi-hour passenger layovers and flexible hub departures, modern mega-airports incorporate massive Early Bag Storage (EBS) systems. Bags checked hours prior to flight departure are stored in high-density automated racking systems serviced by autonomous automated storage and retrieval system (ASRS) robotic cranes. Using RFID inventory tracking, the EBS system retrieves and releases bags onto sorting conveyors in precise flight make-up sequence, drastically cutting apron ramp staging congestion.
Predictive Vibration Monitoring on High-Speed Conveyors and SCADA Systems
To ensure 24/7/365 operational uptime across complex Baggage Handling Systems (BHS), airport maintenance engineering teams deploy centralized Supervisory Control and Data Acquisition (SCADA) architectures integrated with IoT predictive maintenance sensors. High-speed sortation conveyors, cross-belt drive pulleys, and induction belt motors are instrumented with wireless tri-axial vibration accelerometers and thermal infrared sensors.
The SCADA system continuously analyzes vibration spectrums using Fast Fourier Transforms (FFT). Predictive algorithms track specific bearing defect fault frequencies: Ball Pass Frequency Outer Race (BPFO), Ball Pass Frequency Inner Race (BPFI), and Gear Mesh Frequencies (GMF). When a drive pulley bearing begins microscopic spalling, the vibration amplitude at its characteristic BPFO frequency spikes weeks before physical failure occurs. The SCADA system automatically schedules a maintenance work order during off-peak night curfews, replacing the worn bearing without ever interrupting passenger baggage operations.
Baggage conveyor belts incorporate thousands of retro-reflective photoelectric sensors (photocells) spaced along every meter of conveyor line. Programmable Logic Controllers (PLCs) execute anti-piling logic: if a photocell beam remains blocked for longer than a calculated transit threshold (typically 3 to 5 seconds), the PLC instantly flags a potential luggage jam. The upstream conveyor zones decelerate to a complete stop within 500 milliseconds, preventing incoming luggage from piling into a catastrophic multi-bag jam.
Autonomous Mobile Robots (AMR), Robotic Ramp Loading and Biometric Token Integration
The final frontier of airport baggage automation is the transition from fixed conveyor belts toward flexible, infrastructure-free Autonomous Mobile Robots (AMR) and automated aircraft ramp loading systems. In modern apron environments, fleets of autonomous electric AMRs navigate baggage halls and aircraft aprons using LiDAR, stereo computer vision, and SLAM (Simultaneous Localization and Mapping) navigation algorithms.
Rather than relying on kilometers of rigid mechanical conveyor tracks that require multi-million-dollar structural terminal renovations to modify, AMR fleets can be scaled dynamically to handle passenger demand surges. In the baggage make-up area, robotic articulated arms equipped with 3D vision systems autonomously grasp luggage from sortation conveyors, scan RFID chips, and pack unit load devices (ULD containers) using automated 3D bin-packing optimization algorithms. Furthermore, checked baggage tracking is directly linked to the passenger’s Biometric One-ID Token, allowing travelers to monitor real-time luggage location and loading milestones directly on their smartphones from check-in to final carousel delivery.
Major international hub airports are deploying autonomous electric baggage tugs to transport baggage dollies between terminal sorting hubs and aircraft gate stands. Equipped with multi-layer obstacle avoidance LiDAR arrays, GPS-RTK positioning, and vehicle-to-infrastructure (V2X) communications, autonomous tugs safely navigate busy ramp environments, reducing ground vehicle collisions and delivering 99.9% on-time baggage transfer during tight 45-minute aircraft turnarounds.
Integrated Airport Infrastructure Engineering: Airside Systems, Navigation and Automated Terminal Logistics
The seamless operation of international hub airports relies on a sophisticated, multi-layered civil and electronic engineering infrastructure designed to manage high-throughput air traffic, guarantee all-weather runway safety, and process tens of thousands of passengers and luggage items every hour. Airport technology bridges the physical interface between aerial flight operations and ground-based intermodal transit networks.
The operational framework of modern airport infrastructure comprises four essential technical domains:
- Precision Ground-Based Navigation Aids (NAVAIDS): Maintaining ICAO Annex 10 certified Instrument Landing Systems (ILS) comprising VHF Localizer and UHF Glide Slope antenna arrays that modulate 90 Hz and 150 Hz audio tones to provide millimeter-precision lateral and vertical guidance down to Category III zero-visibility autoland touch-downs, backed by emerging Multi-Constellation GBAS satellite landing systems.
- Airside Pavement Tribology and Surface Safety: Mitigating aircraft tire dynamic and viscous hydroplaning risks through high-precision transverse runway grooving (FAA AC 150/5320-12D), continuous friction monitoring with specialized CFME testing trailers, ultra-high-pressure rubber deposit hydro-blasting, and non-corrosive organic de-icing chemical applications.
- Next-Generation Air Traffic Management (ATM): Transforming regional and terminal airspace through ADS-B 1090 MHz Extended Squitter surveillance, space-based satellite tracking, Time-Based Separation (TBS) wake vortex dynamic spacing, and Trajectory-Based Operations (TBO) that eliminate fuel-wasting holding stacks.
- High-Speed Automated Baggage Logistics: Deploying closed-loop tilt-tray and cross-belt sortation networks operating at speeds up to 10 m/s, integrated with UHF RFID chip tracking (IATA Resolution 753) and Standard 3 Computed Tomography (CT) explosive detection systems to process checked luggage with >99.5% accuracy and zero security compromise.
A mega-hub airport represents an extraordinary convergence of civil, electronic, and systems engineering: from precision radio frequency image antennas radiating stable localizer and glide slope course signals, to saw-cut grooved concrete runways preventing dynamic hydroplaning under 400-ton aircraft landings, to automated baggage handling networks sorting 100,000 bags daily via high-speed cross-belt kinematics and RFID telemetry. The flawless execution of these systems ensures safe, efficient, and resilient global commercial air transportation.
Smart Airport Evolution: IoT Environmental Monitoring, Green Electrification and Autonomous Aprons
The future of airport infrastructure is defined by deep sustainability and autonomous operations. Modern hub airports are deploying smart pavement IoT sensor grids that continuously measure sub-surface slab deflection and de-icing chemical concentration, electrifying airside ground support equipment (e-GSE) with high-power fast charging grids, and deploying autonomous robotic luggage tugs and automated aircraft pushback tractors (e.g., TaxiBot)—slashing airport carbon footprints while maximizing turn-around efficiency.